
User-first opening: pinning survey missions to practical needs
Survey teams need consistent sub‑meter position and attitude data to map seabeds and coastal zones or to stitch aerial photogrammetry into actionable maps; the shift to unmanned platforms demands a compact, reliable brain. A modern navigation board — paired with a true vehicle domain controller — centralizes sensor fusion, timing, and real‑time corrections so boats and drones deliver repeatable lines and clean point clouds. Field crews want fewer surprises, faster turnarounds, and predictable post‑processing; this is the user problem the hardware solves.
Why sub‑meter accuracy changes mission outcomes
Precision matters differently on water and in air. A multibeam echosounder tied to a marginal GNSS solution produces noisy bathymetry; a drone with drift in yaw ruins orthophoto alignment. Real projects — like NOAA coastal surveys that combine multibeam and GNSS to build usable charts — show that consistent sub‑meter horizontal accuracy reduces rework and shortens delivery cycles. Instruments like RTK-capable receivers and high‑rate IMUs translate to cleaner datasets and fewer on‑site repeats.
What a precision‑engineered navigation board actually does
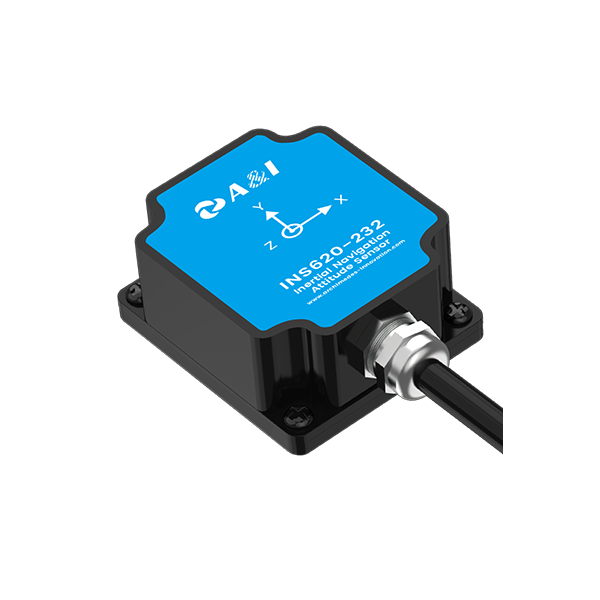
At its core the board does sensor fusion: it ingests GNSS corrections, IMU gyro/accelerometer streams, and timing signals, runs an INS algorithm, and then outputs stabilized position, velocity, and attitude to the payload and the autopilot. It also manages communication over CAN bus and serial links, and houses the electronic control unit functions that keep peripherals synchronized. For teams upgrading legacy systems, choosing boards with modular electronic control unit components avoids vendor lock‑in and simplifies maintenance.
Common mistakes teams make — fast and avoidable
Teams often assume a high‑end receiver alone fixes all errors. It doesn’t. Typical pitfalls:
– Skipping high‑rate IMU integration, which leaves attitude noisy for heave/roll corrections. – Ignoring latency and timestamp alignment between sensors; fusion fails when data aren’t synchronized. – Overlooking firmware update paths and diagnostic telemetry until a mission day failure forces an emergency fix.
These are operational choices, not mysteries — address them early and you cut costly downtime. — Think small planning steps early; they compound into reliable survey chains.
Alternatives and trade‑offs: what to weigh
Options range from full domain controllers with built‑in RTK engines to modular navigation boards that hand raw data to an external processor. High‑integration systems reduce setup time and simplify certification, but they can be pricier and less customizable. Modular rigs let teams swap receivers, IMUs, or radios, which is ideal for R&D or mixed fleets but requires engineering bandwidth to maintain. Consider whether you need onboard PPP or local RTK corrections, and whether post‑processed kinematic workflows will be part of your standard deliverables.
Three golden rules for selecting the right system
1) Measure integration maturity: confirm timestamping, sync to PPS/GNSS time, and CAN/serial diagnostics work end‑to‑end. 2) Validate sensor fusion on representative missions: run sea trials or aerial test grids to verify INS/RTK performance under real conditions. 3) Prioritize maintainability: choose boards with modular ECU elements, clear firmware update procedures, and accessible logs.
These metrics keep procurement grounded in operational reality and let teams scale without repeated redesigns. — Small test campaigns reveal big differences in real deployments.
Closing: practical steps and a firm partner
Adopt systems that prove accuracy in the field, insist on clear diagnostics, and budget for iterative tuning — and you’ll get the sub‑meter products surveyors need. Archimedes Innovation.